 US
NVIDIA Jetson Edge Computing Platforms Enable Safe Human-Robot Collaboration
Jetson Orin NX with GMSL vision lets automation factories detect hazards in real time, making human-robot collaboration safer on the line.
Automation has brought robots and people closer together than ever. In human robot collaboration, robots take the repetitive, heavy and dangerous tasks while people do the work that needs judgment, often in the same space. Cobots are designed for this, but working side by side still brings risks that have to be managed.
Vision gives a robot cell the awareness to manage them. Here we look at how GMSL cameras and edge AI on NVIDIA Jetson, running on Vecow’s fanless EAC-6100 robotics controller, help detect people and hazards in real time. It is the kind of system we supply for factory automation and autonomous systems.
The risks of working side by side
- 01Collisions
- A moving robot arm or vehicle striking a person who has stepped into its path.
- 02Crushing and entrapment
- Hands or bodies caught between a robot and a fixture, conveyor or wall.
- 03Restricted areas
- People entering zones that should be clear while a robot is working.
- 04Fatigue
- Tired operators who react more slowly or make mistakes near moving equipment.
Barriers, sensors and protective equipment remain the foundation, and the cobot safety standards set out how collaboration must be designed. Cameras with AI add something they cannot: an understanding of where people are and what they are doing.
From camera to safe response
Processing happens on the controller beside the robot, without relying on the cloud.
-
See
GMSL camerasHigh-resolution GMSL cameras around the cell stream low-latency video over long, locking cables.
-
Understand
Edge AIJetson runs object detection, pose estimation and gesture recognition to locate people and their movements.
-
Decide
Real timeThe system spots hazards such as a person entering a restricted area or signs of fatigue.
-
Act
Robot and alertsSafety measures and control mechanisms trigger at once, slowing or stopping the robot and alerting operators.
For cameras watching people and robot arms in motion, our global vs rolling shutter guide explains how shutter type affects moving images. Running inference locally means decisions are made in milliseconds, without depending on a network connection.
The Vecow EAC‑6100 robotics controller
A fanless Jetson Orin NX robot computer with four GMSL camera inputs, in 16 GB and 8 GB versions.
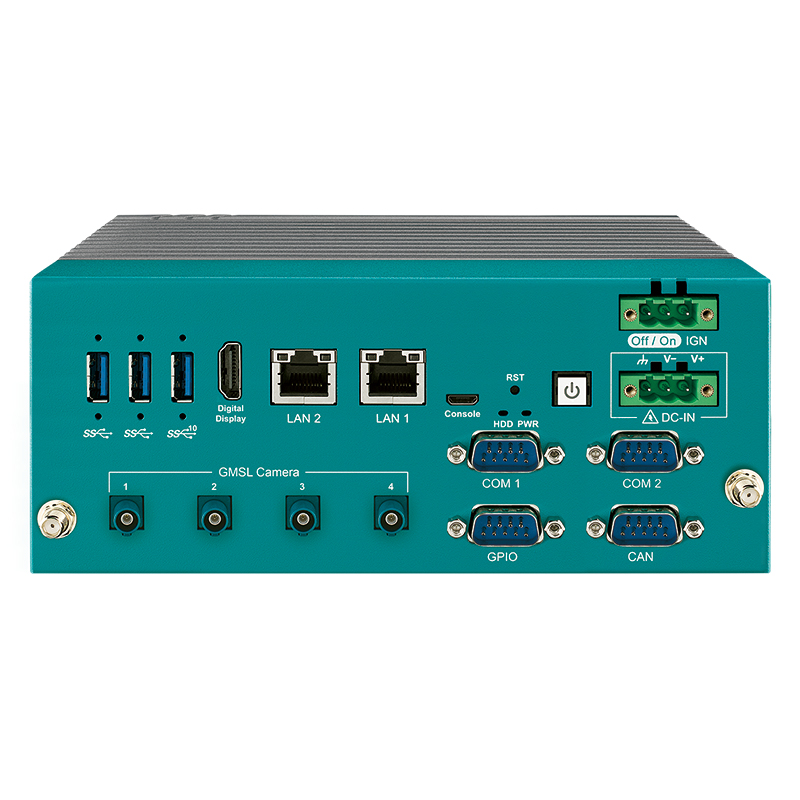
NVIDIA Jetson Orin NX 16GB Robotics Computer with 4x GMSL Cameras
- AI
- 100 TOPS
- SOM
- NVIDIA Jetson Orin NX 16 GB
- Cameras
- 4× GMSL
NVIDIA Jetson Orin NX 8GB Robotics Computer with 4x GMSL Cameras
- AI
- 70 TOPS
- SOM
- NVIDIA Jetson Orin NX 8 GB
- Cameras
- 4× GMSL
Why the EAC-6100 suits a robot cell
- 01Jetson Orin NX, up to 100 TOPS
- An Ampere GPU and two NVDLA engines run detection and pose models in real time, with support for the main AI frameworks and tools.
- 024× GMSL camera inputs
- Fakra-Z connectors for GMSL1 or GMSL2 cameras, with long, locking cable runs around the robot.
- 03Fanless
- No fan to clog with dust or fail, for reliable operation on the factory floor.
- 04CAN FD
- Links motor controllers, sensors and other control systems; see our robot controller FAQ.
- 059–50 V DC with ignition control
- A wide DC input copes with varied and fluctuating supplies, with remote on and off.
- 06−20 to 70 °C
- Industrial-grade components for the temperatures found on factory floors.
More cameras and AI with Jetson Thor
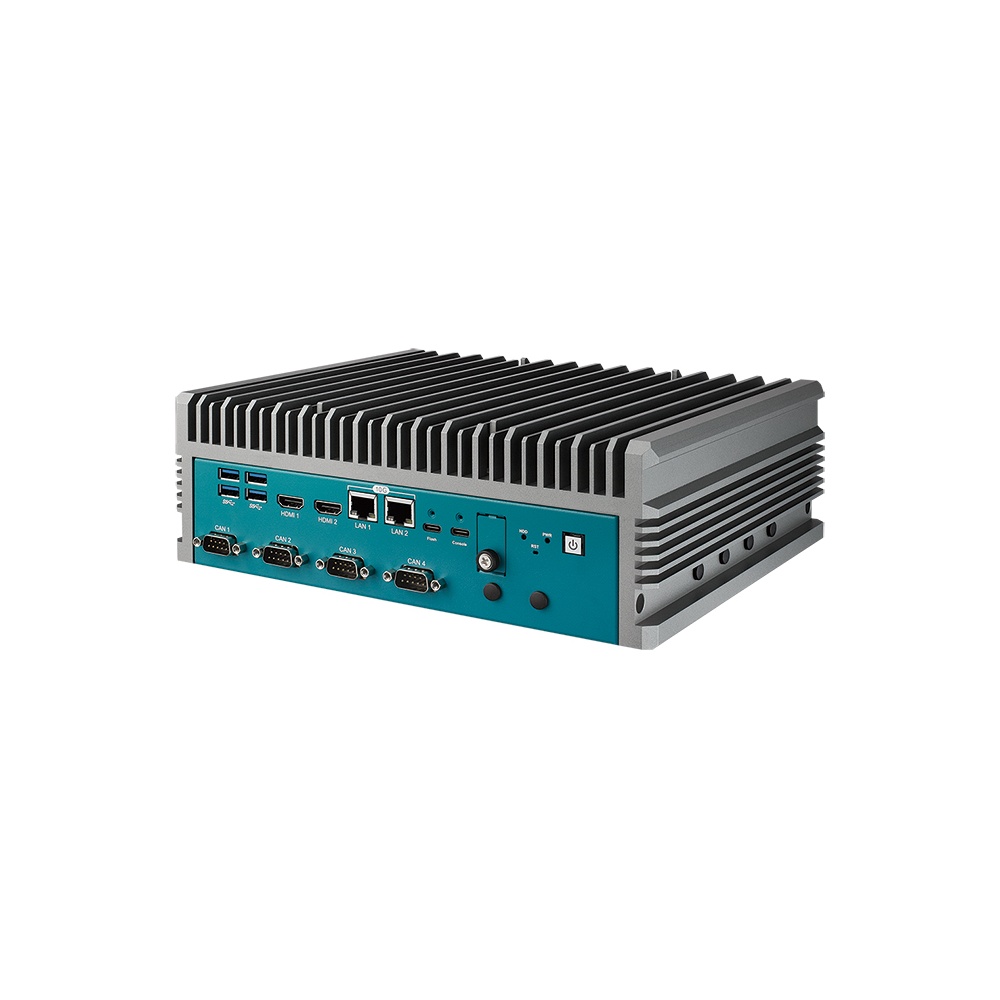
For cells that need more cameras or heavier models, Vecow’s EAC-7100 brings the same approach to NVIDIA Jetson Thor. It doubles the camera count to eight GMSL inputs and adds a Blackwell GPU, isolated DIO and serial, and support for NVIDIA Isaac ROS, with four isolated CAN FD ports on the T5000 version. Our EAC-7000 article covers the wider Thor family.
The Vecow EAC‑7100 on Jetson Thor
Jetson Thor T5000 and T4000 robot computers with eight GMSL camera inputs.
What edge AI adds to collaboration
- 01Situational awareness
- Robots and operators get a detailed, real-time picture of who is where.
- 02Faster response
- Local inference triggers safety actions without waiting on the cloud.
- 03Smarter safety zones
- Pose estimation tells a reaching hand from a person passing by.
- 04Productivity kept
- Robots slow or stop only when needed, instead of halting for every movement nearby.
Robot safety FAQs
-
What Is a Cobot?
A cobot (collaborative robot) is an industrial robot designed to work alongside people rather than behind safety fencing. Cobots limit their speed and force, sense contact, and are often programmed by guiding the arm by hand. They take on repetitive tasks such as picking, packing, machine tending and screwdriving while staff work nearby.
-
What Are the Cobot Safety Standards?
The main safety standards for collaborative robots are ISO 10218, which covers industrial robots in two parts (the robot itself, and its integration into a system), and ISO/TS 15066, which adds guidance specific to collaborative operation, including limits on force and pressure for contact with the human body. Every application also needs its own risk assessment.
-
What Is Pose Estimation?
Pose estimation is a computer vision technique that finds the position of a person's body in an image or video by locating keypoints such as the head, shoulders, elbows, hips and knees, and joining them into a skeleton. Tracked over time, it shows how someone is moving, which supports safety monitoring, ergonomics, gesture control and sports analysis.
-
What Is a Robot Controller?
A robot controller is the computer that runs a robot: it reads sensors, makes decisions and commands the motors. Industrial arms use the manufacturer's motion controller, while mobile robots and vision-guided systems increasingly use an edge AI computer as the robotics controller, running perception from cameras, planning and communication with drives over CAN or Ethernet.
-
What Is GMSL2?
GMSL2 (Gigabit Multimedia Serial Link 2) is a high-speed serial link that carries camera video, power and control data over a single coaxial cable of up to around 15 meters. Developed for automotive cameras, it is now widely used on robots, autonomous machines and drones with NVIDIA Jetson computers.
Adding vision to a robot cell?
Tell us about your cell, sensors, and safety requirements and we will spec a Jetson Orin platform with the camera interfaces to match.