 UK
Vecow EAC-7000: a Jetson Thor AI computer for robotics and autonomy
The Vecow EAC-7000 brings NVIDIA Jetson Thor — 2,070 FP4 TFLOPS of Blackwell-generation AI — to robotics, humanoid, and autonomous-machine platforms, with up to 16 GMSL cameras and 10 Gigabit networking.
The Vecow EAC-7000 is a robot and autonomous-machine computer built on Jetson Thor, the Blackwell-generation module that delivers up to 2,070 FP4 TFLOPS of AI. It wraps Thor in the camera inputs, networking and machine I/O that physical-AI platforms need, and it is one of the first Thor systems we supply.
It is aimed at machines that perceive and act in the real world: AI-based robots, humanoid robots and automated agricultural machinery. Thor brings what was data-centre-class inference down to a module that can sit inside a machine, and our look at how Jetson Thor moves edge AI beyond AGX Orin sets out what has changed.
Five configurations, one Thor core
Every EAC-7000 shares the same Jetson Thor core; the five configurations differ in sensor I/O, and each comes with the T4000 or, on F models, the T5000 module.
| Configuration | Adds |
|---|---|
| EAC-7000 | Base computer: 2× 2.5GbE, DIO, serial, M.2 wireless |
| EAC-7100 | 8× GMSL cameras |
| EAC-7200 | 16× GMSL cameras and 2× 10GbE |
| EAC-7300 | 4× GbE PoE+ |
| EAC-7400 | 2× 10GbE and 2× 10GbE PoE+ (T5000 only) |
Models with an F suffix carry the T5000 module and add four isolated CAN FD ports. The optional IMU, magnetometer, altimeter and TPM make it a fit for autonomous and mobile platforms.
EAC‑7000 models
Nine models across five I/O configurations; these four show the range, from the base computer to 16 cameras and 10GbE PoE+.
NVIDIA Jetson Thor T4000 Fanless Robot Computer
- AI
- 1,200 TOPS
- SOM
- NVIDIA Jetson T4000
- Ethernet
- 2× 2.5GbE
NVIDIA Jetson Thor T5000 Robot Computer with 8x GMSL Cameras and CAN-FD
- AI
- 2,070 TOPS
- SOM
- NVIDIA Jetson T5000
- Cameras
- 8× GMSL
NVIDIA Jetson Thor T5000 Robot Computer with 16x GMSL, 10GbE and CAN-FD
- AI
- 2,070 TOPS
- SOM
- NVIDIA Jetson T5000
- Cameras
- 16× GMSL
NVIDIA Jetson Thor T5000 Robot Computer with 10GbE PoE+ and CAN-FD
- AI
- 2,070 TOPS
- SOM
- NVIDIA Jetson T5000
- Ethernet
- 4× 10GbE, 2× 2.5GbE (2× PoE)
What the EAC-7000 brings
- 012,070 FP4 TFLOPS
- NVIDIA Jetson Thor T5000 with 128 GB LPDDR5X and a 14-core Arm Neoverse CPU, or T4000 with 64 GB and 12 cores.
- 02Robotics software ready
- Ubuntu 24.04 and JetPack 7, with NVIDIA Isaac Perceptor on Isaac ROS and the Holoscan Sensor Bridge for low-latency sensor data.
- 03Up to 16 GMSL cameras
- Eight GMSL 1/2 automotive camera inputs on FAKRA Z (EAC-7100) or sixteen on Mini-FAKRA (EAC-7200), for dense multi-camera perception.
- 0410 Gigabit and PoE+
- Up to four 10GbE ports, two of them PoE+, or four GbE PoE+ ports, alongside two 2.5GbE on every model.
- 05Rich machine I/O
- Four isolated CAN FD on the T5000 models, 16 isolated DIO, serial, 5G or 4G, and 9–50 V DC with ignition control.
Specification highlights
| Specification | Vecow EAC-7000 |
|---|---|
| Module | NVIDIA Jetson Thor T5000 (128 GB) / T4000 (64 GB) |
| AI performance | Up to 2,070 FP4 TFLOPS |
| CPU / GPU | 14-core (T5000) or 12-core (T4000) Arm Neoverse V3AE; NVIDIA Blackwell GPU |
| Cameras | 8× or 16× GMSL 1/2 (EAC-7100 / EAC-7200) |
| Networking | 2× 2.5GbE on every model; up to 4× 10GbE or 4× GbE PoE+; M12 X-coded option |
| Machine I/O | 4× isolated CAN FD (T5000 models), 16× isolated DIO, 2× RS-232/422/485, 4× USB 3.1 |
| Display and wireless | 2× HDMI up to 8K; 5G / 4G / Wi-Fi on M.2 Key B and Key E, 2× nano SIM |
| Software | Ubuntu 24.04, JetPack 7, NVIDIA Isaac ROS |
| Power | 9–50 V DC, 16-mode software ignition control |
| Environment | −20 to 45 °C fanless at 77 W, to 70 °C with fan sink; MIL-STD-810G shock and vibration; EN 50155 EMC |
A closer look
-
01

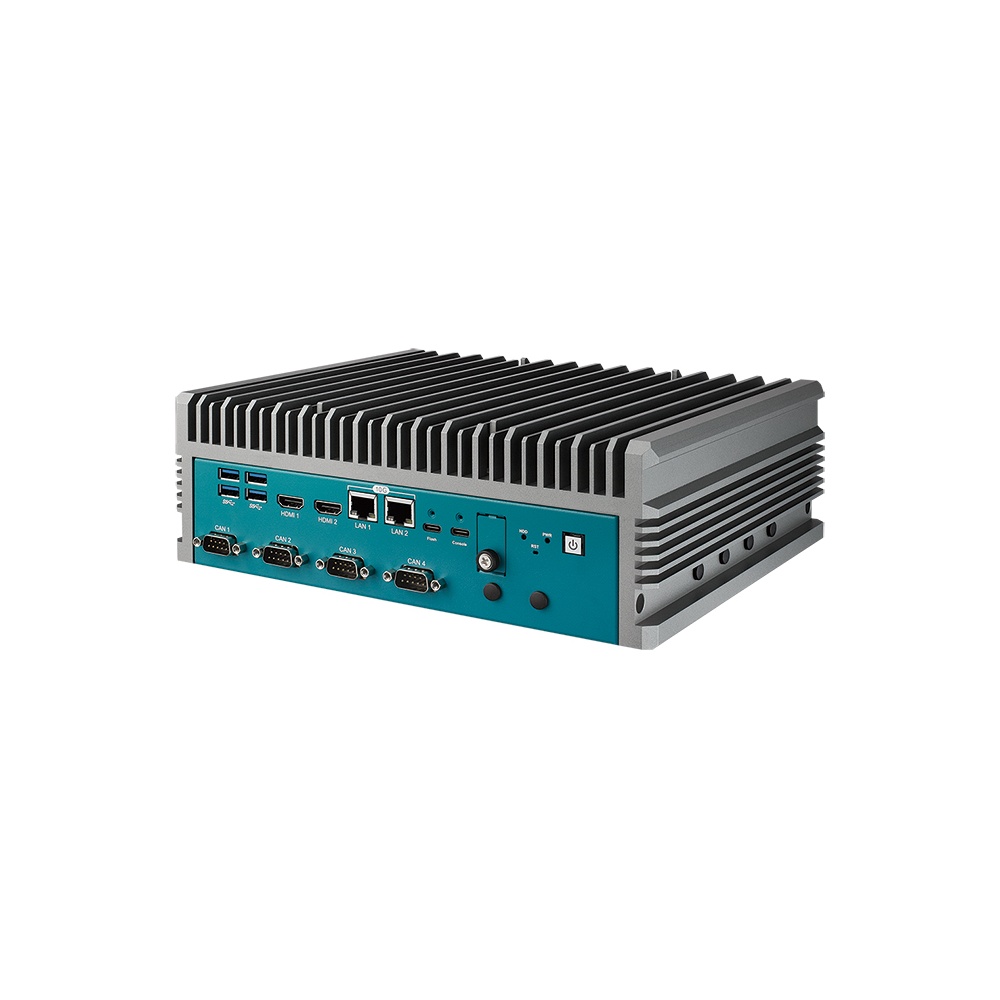
Fanless Jetson Thor computer
The EAC-7000 in its finned heatsink chassis, with HDMI, USB, LAN and serial ports on the front.
-
02
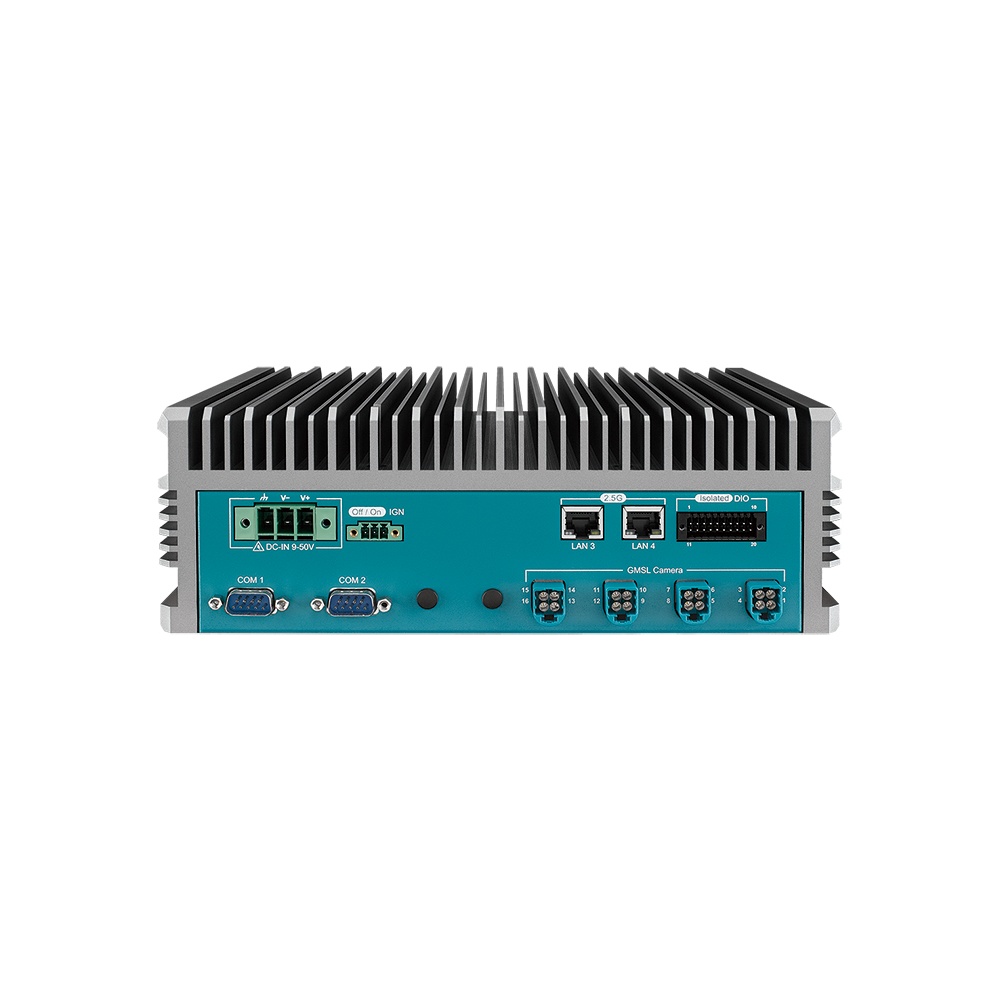
GMSL camera panel
DC input, dual serial, LAN, isolated DIO and four GMSL connectors, which carry 16 cameras on the EAC-7200.
Where the EAC-7000 fits
Machines that fuse far more sensor data than a single-camera edge device, and run large models while they move.
Humanoid and AI robots
Many cameras and sensors fused at once, with room for large vision-language models on the T5000.
Autonomous mobile robots
Perception paired with navigation, with CAN FD to the drive system and ignition-aware power.
Surround-view vehicles
Up to 16 GMSL automotive cameras feeding one computer for surround-view perception.
View range
Networked sensor robots
IP cameras and lidar powered from the PoE+ ports, with no separate switch to carry.
Agricultural machinery
Long-running outdoor vision on automated farm machines, with 5G or 4G back to base.
Why sensor bandwidth matters
Thor is built for physical AI: generative and reasoning models running on a machine that has to move and respond in real time. What ties the EAC-7000’s target machines together is sensor density, which is why the configurations scale to 16 cameras and four 10GbE ports, and why the Holoscan Sensor Bridge is supported for low-latency sensor pipelines.
From module to robot
Thor is a new module generation, so a build on it is a platform design, not a refresh of an Orin system. The value is in the integration.
-
Configure
Model and moduleWe match the configuration to the workload: T5000 or T4000, camera count, 10GbE or PoE+, and CAN FD where the machine needs it.
-
Connect
Cameras and sensorsCameras and sensors are wired across GMSL and Ethernet, using GMSL camera interfaces matched to the platform.
-
Bring up
JetPack and IsaacThe JetPack 7 and Isaac ROS software image is loaded and configured for the sensor set.
-
Validate
Under loadThe whole stack is tested under load, including thermal behaviour in fanless or fan-sink form, before the system ships.
Choosing a Thor platform
If you are weighing Thor against Orin, our guide to choosing a Jetson module covers the lineup. For defence programmes that need full military qualification, the Forecr MILBOX‑THR military-grade Thor computer puts the same module into an IP67 enclosure.
EAC-7000 FAQs
-
Jetson T5000 vs T4000: What Is the Difference?
The Jetson T5000 and T4000 are the two NVIDIA Jetson Thor modules. The T5000 is the top variant, with up to 2,070 FP4 TFLOPS, 128 GB, and up to 130 W; the T4000 is the lower-power variant, with up to 1,200 FP4 TFLOPS, 64 GB, and up to 70 W. Both use the Blackwell GPU.
-
Does Jetson Thor Need a New Carrier Board?
Yes. Jetson Thor uses a different connector, higher power (up to 130 W), and new I/O compared with AGX Orin, so it needs a carrier board designed for Thor rather than an Orin board. Moving from AGX Orin to Thor is a platform change, not a drop-in module swap.
-
What Is NVIDIA JetPack?
NVIDIA JetPack is the software development kit for the Jetson platform. It provides the operating system (Linux for Tegra, based on Ubuntu) plus the AI, computer-vision, and multimedia libraries — CUDA, cuDNN, and TensorRT — that let a Jetson run GPU-accelerated AI. The same JetPack runs across the Jetson range.
-
What is 10GbE networking?
10 Gigabit Ethernet — the networking standard increasingly used as the practical baseline for edge AI workloads handling high-resolution video, multi-sensor telemetry, and distributed inference.
-
When should you upgrade from 2.5GbE to 10GbE?
Upgrade when edge AI workloads involve multi-camera analytics, multi-sensor fusion, multi-node inference, or latency-sensitive control where networking CPU overhead is limiting performance.
-
PoE vs PoE+ vs PoE++: The 802.3af, 802.3at and 802.3bt Standards
802.3af (PoE), 802.3at (PoE+) and 802.3bt (PoE++) are the three IEEE Power over Ethernet standards. They differ mainly in power per port, roughly 15 W, 30 W, and up to 60 to 90 W, with the higher tiers using all four pairs of the cable.
Planning a Jetson Thor build?
Tell us the robot or machine and the sensors it carries. As your system integrator we will configure the EAC-7000 to the application and deliver a deployable platform.