
 UK
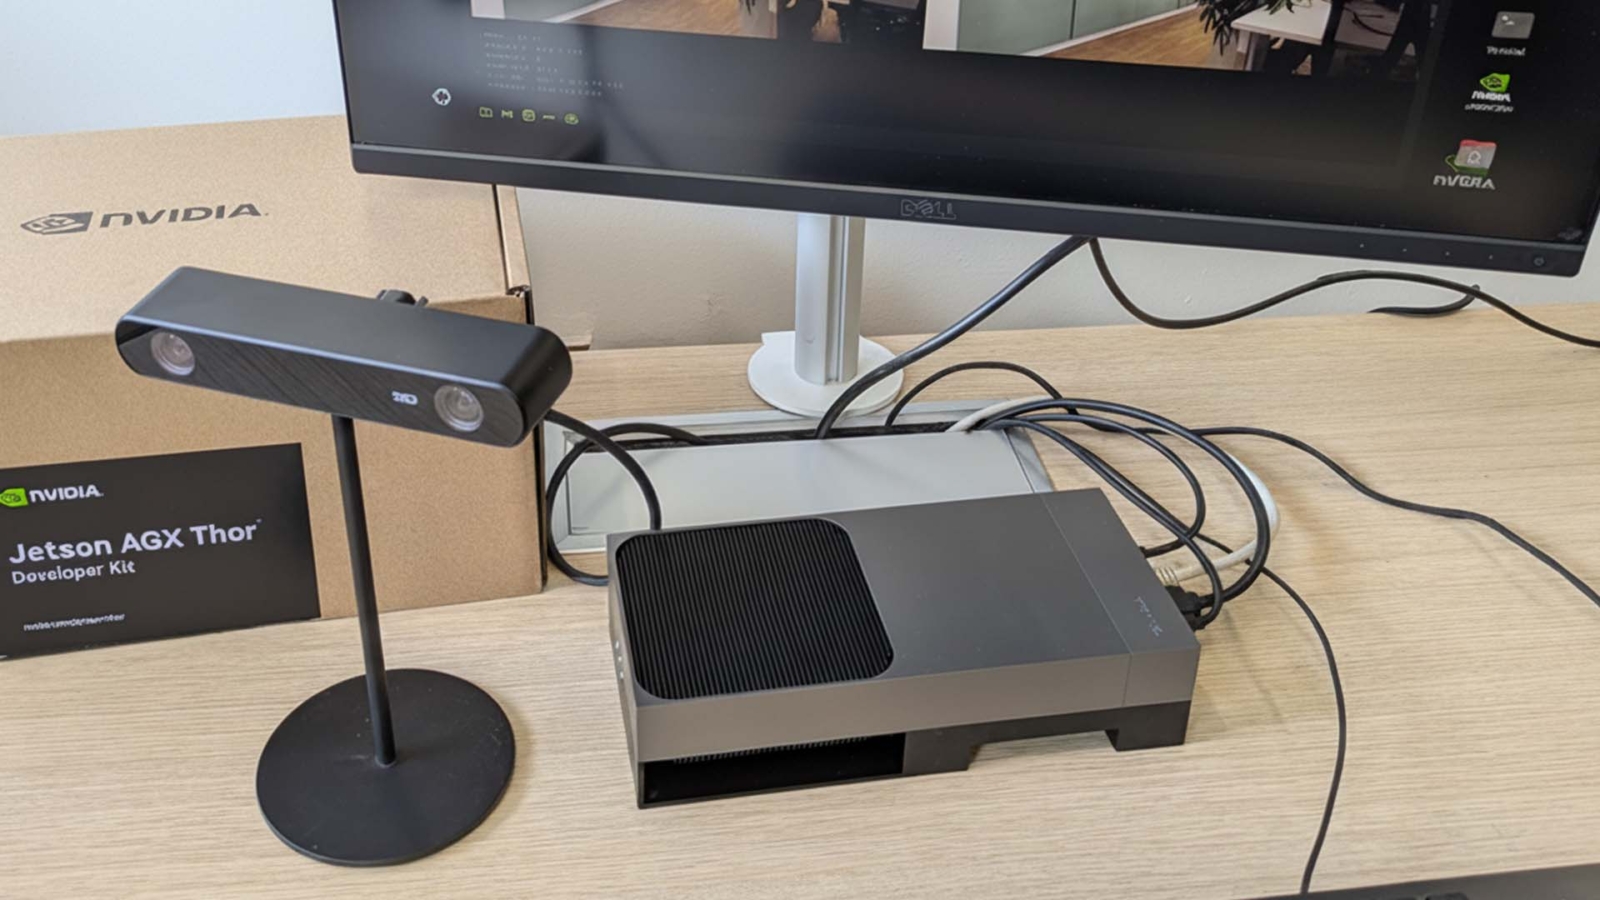
Jetson Thor Specs: T5000 and T4000 vs AGX Orin
Jetson Thor brings a Blackwell GPU, up to 2,070 FP4 TFLOPS and 128 GB of memory to the edge. Here is how the T5000 and T4000 compare with AGX Orin, what the figures mean and what a move to Thor changes.
Jetson Thor vs Orin is the step from NVIDIA’s Ampere generation to Blackwell. On Jetson Thor specs, the T5000 module is rated at up to 2,070 FP4 TFLOPS with 128 GB of memory, against 275 INT8 TOPS and 64 GB on the AGX Orin 64GB. NVIDIA puts the gain at up to 7.5 times the AI compute and 3.5 times the energy efficiency, at a power envelope that rises from 60 W to 130 W.
Jetson Thor combines a 14-core Arm Neoverse-V3AE CPU with a Blackwell GPU and its transformer engine, and it is built for the workloads Orin struggles to hold: humanoid robots, mobile manipulators and machines that run perception, planning and language models at once. Jetson AGX Orin remains in production and is still the right module for a great deal of edge AI.
This guide compares the two generations side by side, explains why the TFLOPS and TOPS figures are not like-for-like, and covers what changes in the carrier board, power, cooling and software when a design moves up. For where both sit in the wider lineup, start with what NVIDIA Jetson is and why it runs AI at the edge.
Key takeaways
- 01Up to 7.5× the AI compute
- NVIDIA’s figure for the T5000 against AGX Orin; it compares FP4 with INT8, so real models gain less on paper and more where memory was the limit.
- 02Two Thor modules
- The T5000 has 128 GB and runs at 40–130 W; the T4000 has 64 GB and runs at 40–70 W. Both use Blackwell and JetPack 7.
- 03Memory is the bigger change
- 128 GB of LPDDR5X at 273 GB/s lets large language and vision language models run on board.
- 04Not a drop-in upgrade
- Thor needs a Thor carrier board, a larger power supply, new cooling and a rebuild on JetPack 7.
- 05AGX Orin still fits many jobs
- For detection and tracking on a few cameras, AGX Orin is lower in power and well proven.
Jetson Thor vs AGX Orin: the specifications
The table sets the two Thor modules beside the two commercial AGX Orin modules, using NVIDIA’s published figures. Interface counts differ between modules and carriers, so treat the I/O rows as module capability and check the datasheet for the exact numbers.
| Specification | AGX Orin 32GB | AGX Orin 64GB | Jetson T4000 | Jetson T5000 |
|---|---|---|---|---|
| GPU architecture | Ampere | Ampere | Blackwell | Blackwell |
| GPU | 1,792 cores, 56 Tensor Cores | 2,048 cores, 64 Tensor Cores | 1,536 cores, 64 fifth-generation Tensor Cores | 2,560 cores, 96 fifth-generation Tensor Cores |
| AI performance | 200 TOPS (sparse INT8) | 275 TOPS (sparse INT8) | 1,200 FP4 TFLOPS (sparse) | 2,070 FP4 TFLOPS (sparse) |
| CPU | 8-core Arm Cortex-A78AE | 12-core Arm Cortex-A78AE | 12-core Arm Neoverse-V3AE | 14-core Arm Neoverse-V3AE |
| Memory | 32 GB LPDDR5, 204.8 GB/s | 64 GB LPDDR5, 204.8 GB/s | 64 GB LPDDR5X, 273 GB/s | 128 GB LPDDR5X, 273 GB/s |
| Module power | 15–40 W | 15–60 W | 40–70 W | 40–130 W |
| Fastest Ethernet | 10GbE | 10GbE | Multi-gigabit up to 25GbE | Up to four 25GbE links |
| PCI Express | Gen 4 | Gen 4 | Gen 5 | Gen 5 |
| GPU partitioning | No | No | Multi-Instance GPU | Multi-Instance GPU |
| Software | JetPack 6, JetPack 7.2 | JetPack 6, JetPack 7.2 | JetPack 7 | JetPack 7 |
| Carrier board | 699-pin AGX Orin carriers | 699-pin AGX Orin carriers | Thor carriers | Thor carriers |
Two rows matter more than the AI figures. Memory doubles from 64 GB to 128 GB on the T5000, with about a third more bandwidth, and that decides which models fit at all. Power more than doubles at the top end, and that decides the carrier, the supply and the enclosure. Our answer on Jetson T5000 vs T4000 compares the two Thor modules in more detail, and our Jetson modules comparison places all nine current modules side by side.
How much faster is Jetson Thor than AGX Orin?
NVIDIA quotes the T5000 at up to 7.5 times the AI compute of AGX Orin and 3.5 times the energy efficiency. Both figures are real, but the headline compares different precisions, so it needs reading carefully.
| NVIDIA claim against AGX Orin | What it compares | How to read it |
|---|---|---|
| Up to 7.5× AI compute | 2,070 sparse FP4 TFLOPS against 275 sparse INT8 TOPS | FP4 is half the width of INT8; models that hold accuracy at FP4 gain most |
| Up to 3.5× energy efficiency | AI throughput per watt across the power range | Thor does more work per watt, but its total power is higher |
| About 2.6× CPU performance | 14 Neoverse-V3AE cores against 12 Cortex-A78AE cores | Speeds pre-processing, planning, ROS nodes and system code |
| 128 GB against 64 GB | Memory capacity on the T5000 | Lets larger models and longer context run on board |
Precision is the key. Blackwell Tensor Cores run FP4 natively, and NVIDIA quotes Thor at that precision; Orin is quoted at INT8. A model quantised to INT8 on both gains less than the 7.5× headline suggests, while a transformer that would not fit in 64 GB, or ran too slowly to be useful, can go from impractical on Orin to real time on Thor. Our explainers on TFLOPS and how they differ from TOPS and on NVIDIA Blackwell cover the background.
Worked example. A mobile manipulator runs a detector on four cameras, a depth network and a vision language action model. On AGX Orin 64GB the detector and depth network fit comfortably, but the language model has to be cut down to fit beside them, and it answers in seconds rather than fractions of one. On a T5000 the full model, the perception stack and their buffers fit in 128 GB with room to spare, and FP4 inference brings the response into the control loop. The same robot running only the detector and depth network would see a much smaller gain, and AGX Orin would be the more efficient choice.
Which Thor module: T5000 or T4000?
Memory usually decides. The T5000’s 128 GB allows the largest generative and vision language models, longer context or several large models side by side, and suits humanoids and multi-sensor fusion with many high-resolution cameras. Where the models fit comfortably in 64 GB, the T4000 gives Blackwell performance in 40–70 W, which is far easier to cool in a compact or sealed enclosure and kinder to a battery. The two share a form factor and software, so development can start on the T5000 developer kit and production can use either; benchmark the real model on both before fixing the choice.
Sensor fusion: why networking changes with Thor
Perception is where autonomy starts, and Thor is built to move far more sensor data than AGX Orin. The difference shows up as soon as the camera count and resolution rise.
| Sensor set | Approximate raw data rate | AGX Orin path | Thor path |
|---|---|---|---|
| Four 1080p30 cameras | About 4 Gb/s uncompressed | MIPI CSI-2 or GMSL2 through the carrier | Same, with headroom |
| Eight 1080p30 cameras | About 8 Gb/s | 16 CSI lanes or a GMSL2 frame grabber; near the limit | GMSL2 or Ethernet sensor bridges |
| Four 4K30 cameras plus lidar | About 16 Gb/s plus lidar | Beyond 10GbE; usually compressed at the camera | Up to four 25GbE links into GPU memory |
| Several lidars and radars with cameras | Varies with sensor count | Split across systems or downsampled | Consolidated on one module |
The rates assume uncompressed 8-bit YUV video at about 1 Gb/s per 1080p30 stream; compressed IP cameras need far less bandwidth but add decode load and latency. With four 25GbE links and the Holoscan Sensor Bridge, Thor can take raw sensor data into GPU memory without a CPU copy, and MIG keeps the perception, mapping and planning pipelines from competing for the same GPU resources. On AGX Orin the same sensor set usually means compressing at the camera, adding a frame grabber or splitting the work across two computers.
For camera links, our guide to GMSL technology for industrial edge AI explains why automotive cameras dominate robots and vehicles, and our answer on Precision Time Protocol covers how Ethernet sensors stay in time with each other.
Thor and Orin lifecycle
Lifecycle points the same way as performance. Thor is NVIDIA’s newest Jetson generation, from 2025, and AGX Orin is listed in production into the early 2030s, so both are sound choices for a new design. Our answer on how long NVIDIA Jetson is supported sets out the lifecycle of each generation; confirm dates on NVIDIA’s lifecycle page before committing a long programme.
Is Jetson Thor compatible with Orin carrier boards?
No. Thor uses a new module connector, a higher power envelope and new high-speed I/O, so an AGX Orin carrier board cannot take a Thor module. Our answer on whether Jetson Thor needs a new carrier board sets out why. The T4000 and T5000 share the Thor form factor, so a Thor carrier is usually designed for both, within the power and cooling it was built for.
| Area | AGX Orin design | What changes for Thor |
|---|---|---|
| Connector | 699-pin AGX Orin connector | Thor module connector; Orin boards do not fit |
| Power stage | Sized for up to 60 W (75 W Industrial) | Sized for up to 130 W on the T5000, plus the carrier |
| Cooling | Large heatsink or conduction | Heatsink, cold plate or fan rated for the chosen Thor mode |
| High-speed I/O | 10GbE, PCIe Gen 4 | 25GbE, PCIe Gen 5 NVMe and sensor bridges |
| Software | JetPack 6 or 7.2 | JetPack 7; models rebuilt with its TensorRT |
Our Jetson Thor carrier boards include boards with QSFP28 25GbE, CAN FD and camera expansion, and military-grade boards with quad 10GbE and PCIe Gen 5 NVMe. Existing Orin systems stay supported on AGX Orin carrier boards, so there is no need to move before the workload calls for it.
Moving an AGX Orin design to Thor
A move to Thor is best run as a new hardware revision. These are the steps we follow with customers.
-
Profile
Workload on ThorRun the real application on a Thor developer kit to confirm the gain and choose between the T5000 and T4000.
-
Power
Supply and batterySize the supply for the top mode plus the carrier, cameras and storage; vehicle and robot inputs may need to grow.
-
Carrier
Board and enclosureChoose an off-the-shelf Thor carrier or a new design that keeps the existing connector layout where possible.
-
Software
JetPack 7 rebuildPort the application to JetPack 7, rebuild the TensorRT engines and re-validate accuracy and timing.
-
Pilot
Thermal sign-offRun a pilot batch at the top of the temperature range before rollout.
Thermal and power design for a 130 W module
Thor raises the cooling job more than any previous Jetson step. AGX Orin tops out at 60 W on the commercial module; the T5000 runs to 130 W, and a complete system draws more. Catalogue ratings from our range show what that means in practice.
| System | Module | Thermal or power rating from the manufacturer |
|---|---|---|
| Forecr DSBOX‑THRMAX‑T5000 | Jetson T5000 | Draw of 164 W at 24 V at MAXN, with a fan kit for sustained full power |
| Vecow EAC-7000-T4000 | Jetson T4000 | Fanless from −20 °C to 45 °C in 77 W mode, or to 70 °C with the fan sink |
| Advantech MIC-742-AT-T5000 | Jetson T5000 | −10 °C to 60 °C with 0.7 m/s airflow, fan-cooled |
Power budget example. A T5000 robot computer at its top mode, plus eight GMSL2 cameras, two NVMe drives and a 5G modem, can approach 170–200 W at the input. On a 48 V robot battery that is around 4 A continuous before the motors; on a 24 V vehicle supply, around 8 A. A capped mode, such as 70 W or 90 W, often keeps most of the performance with far less heat and current.
The lower power modes are the main design lever. Running a T5000 in a capped mode, or choosing the T4000 at up to 70 W, can make a fanless or sealed design practical. Our Jetson thermal design guide covers heatsinks, fans and conduction cooling, and our answer on conduction cooling explains the sealed-enclosure route.
Software: JetPack 7, Isaac, Holoscan and generative AI
Thor runs JetPack 7, built on Ubuntu 24.04 with CUDA 13, current TensorRT, a PREEMPT_RT real-time kernel option and support for Triton inference serving. JetPack 7.2 then brought AGX Orin and Orin NX onto the same software line, so a fleet can run one generation of software across both. Our guide to NVIDIA JetPack explains the stack, and JetPack 7.2 and Yocto for production Orin fleets covers how the two lines meet.
| Software feature | On AGX Orin | On Thor |
|---|---|---|
| JetPack line | JetPack 6 on Ubuntu 22.04; JetPack 7.2 | JetPack 7 on Ubuntu 24.04 |
| CUDA | 12.x on JetPack 6; 13 on JetPack 7.2 | 13 |
| GPU partitioning | Not available | Multi-Instance GPU splits one GPU into isolated instances |
| Sensor input | MIPI CSI-2, GMSL2 through carriers, Ethernet | As Orin, plus Holoscan Sensor Bridge streaming into GPU memory |
| Generative AI | Small language and vision language models | Larger language, vision language and vision language action models |
Two features change how a Thor system is designed. Multi-Instance GPU lets perception, mapping and planning each run in their own GPU slice with dedicated compute and memory, so one workload cannot starve another. And NVIDIA Holoscan with its sensor bridge moves camera, lidar and radar data over Ethernet straight into GPU memory, cutting CPU hand-offs and latency. Robotics stacks build on ROS through Isaac ROS, and the larger memory makes vision language models practical on board.
CUDA code usually carries across from Orin with little change. What has to be redone is the operating system image, the carrier’s board support package and every TensorRT engine, because engines are built for one GPU and one TensorRT version.
Where Thor makes sense, and where AGX Orin still fits
Thor consolidates perception, sensor fusion and AI reasoning on one module, so a robot or machine can process more sensors in parallel and run larger models without an external server. That pays off in some applications far more than others.
| Application | Why Thor | When AGX Orin still fits |
|---|---|---|
| Humanoid robots | Vision for locomotion, recognition and manipulation at once, with MIG keeping pipelines apart | Research platforms with lighter perception |
| Manufacturing | Inspection, bin picking, quality checks and worker safety on one module | Single-task inspection on a few cameras |
| Logistics and warehousing | Wide-field 3D vision for AMRs and forklifts with more sensors per vehicle | AMRs with two to four cameras and classic navigation |
| Smart facilities | Safety monitoring, flow analytics and asset tracking consolidated on fewer systems | Per-camera analytics at the edge of a site |
| Medical and surgical systems | Several high-resolution video streams processed with low latency | Single-stream imaging assistance |
Choose AGX Orin where the models are classic detection, segmentation and tracking, where the power budget is tight, or where a mature, proven carrier and long field history matter more than headroom. Choose Thor where generative models, many high-resolution sensors or several large models at once are part of the design, or will be within the product’s life.
Our robot computer guide sizes onboard compute by robot class, and Orin NX vs AGX Orin covers the step below.
From prototype to deployment
Developer kits are invaluable for bringing up software, but they are not built for long-life operation in a vehicle, a factory or outdoors. Deployed Thor systems need a carrier board and enclosure designed for the environment, wide-temperature components, shock and vibration resistance and a cooling design matched to the power mode.
Two routes are open. A finished computer, such as the Vecow EAC-7000 for robots and autonomous machines, suits most projects. A rugged carrier board, such as the Forecr MILBOARD‑THR mil-grade Jetson Thor carrier board, suits programmes that build their own enclosure. Either way, we pair the module with the carrier, storage and cooling the application needs, then configure, image and test the system before it ships, so what arrives is a validated computer rather than a board on a bench.
Categories around a Thor or AGX Orin build
The systems, cameras and capture hardware that sit around Thor and AGX Orin.

Edge AI computers
AI systems from Jetson to x86 with GPUs and NPUs.
View range
GMSL cameras
Automotive-grade cameras for long cable runs on robots and vehicles.
View range
Rugged GPU computers
Where a full-size GPU card is the better form factor.
View range
Rugged Jetson computers
Jetson systems for vibration, wide temperature and vehicle power.
View range
GMSL frame grabbers
Add synchronised GMSL2 cameras to Thor and Orin systems.
View range
Military computers
Sealed Jetson systems designed to meet military standards.
View rangeJetson Thor systems and boards
Four Thor builds from our range: a T5000 industrial AI computer with 25GbE and CAN FD, a T4000 industrial box PC, a fanless T4000 robot computer and a T5000 military-grade carrier board.
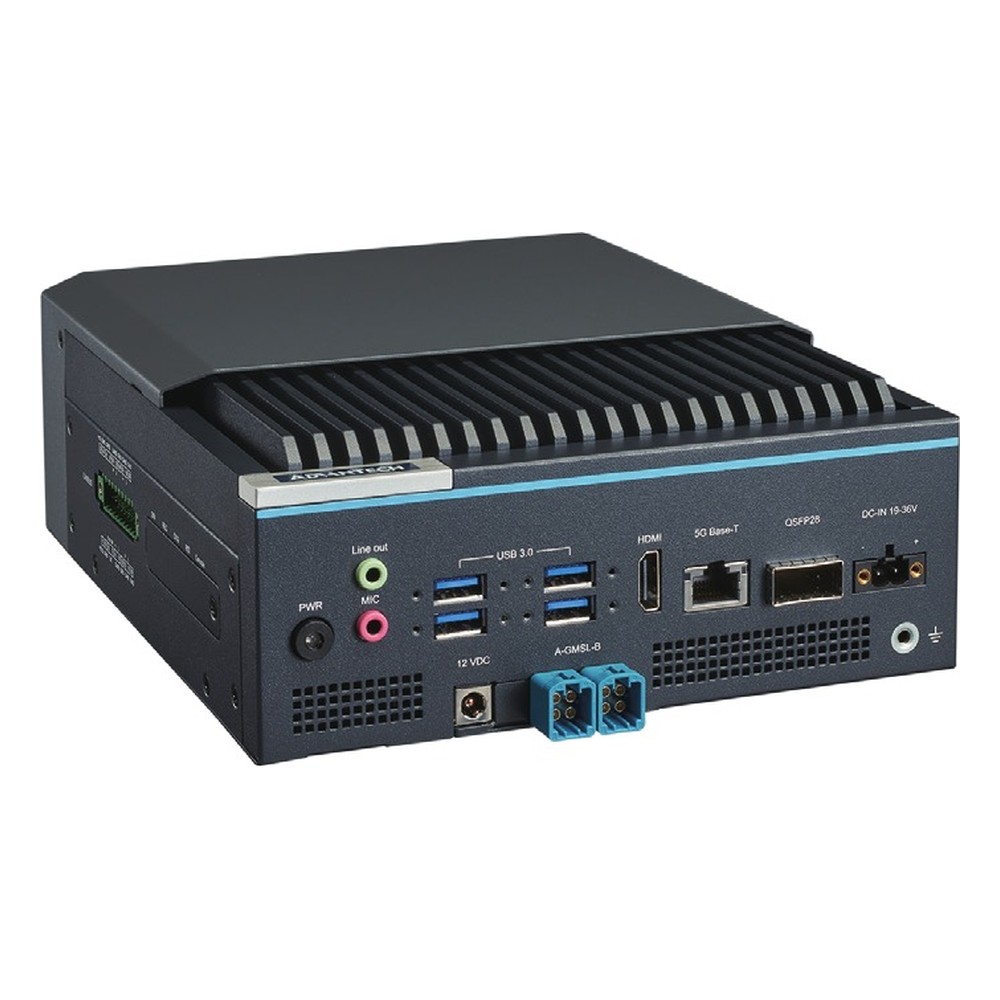
NVIDIA Jetson Thor T5000 Industrial AI Computer with 4x 25GbE QSFP28, 4x CAN FD and 8-Channel GMSL2 Option
- AI
- 2,070 TOPS
- SOM
- NVIDIA Jetson T5000
- Ethernet
- 4× 25GbE, 1× 5GbE
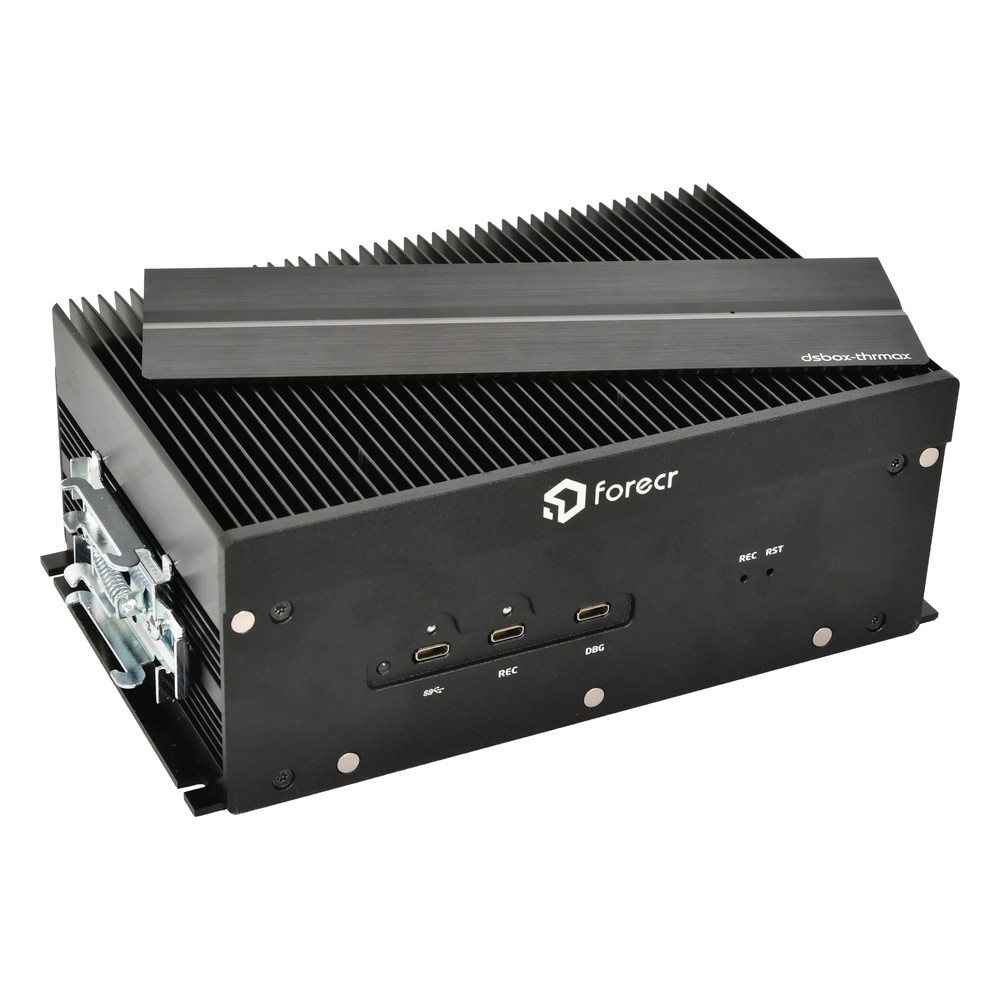
NVIDIA Jetson AGX Thor T4000 Industrial Box PC with 4x 25GbE QSFP28, Dual HDMI and Optional 8x GMSL2
- AI
- 1,200 TOPS
- SOM
- NVIDIA Jetson T4000
- Ethernet
- 4× 25GbE, 1× GbE
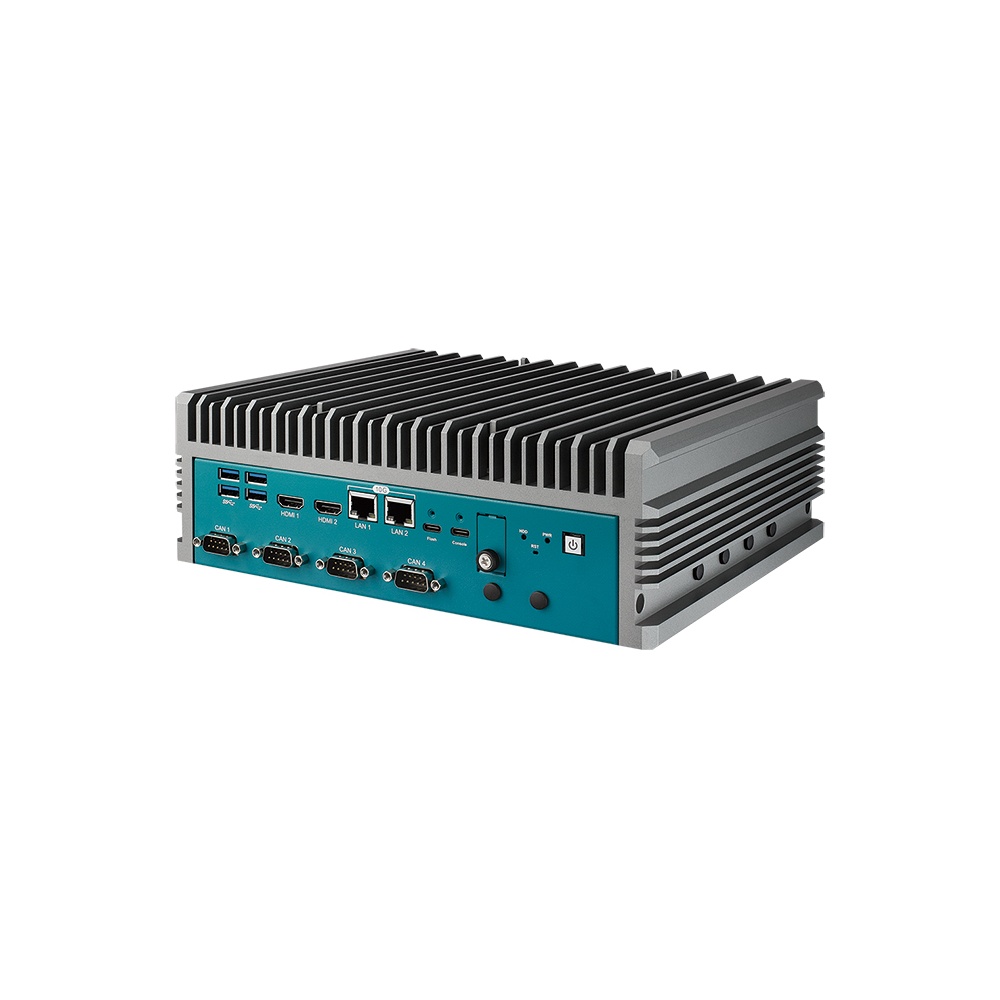
NVIDIA Jetson Thor T4000 Fanless Robot Computer
- AI
- 1,200 TOPS
- SOM
- NVIDIA Jetson T4000
- Ethernet
- 2× 2.5GbE
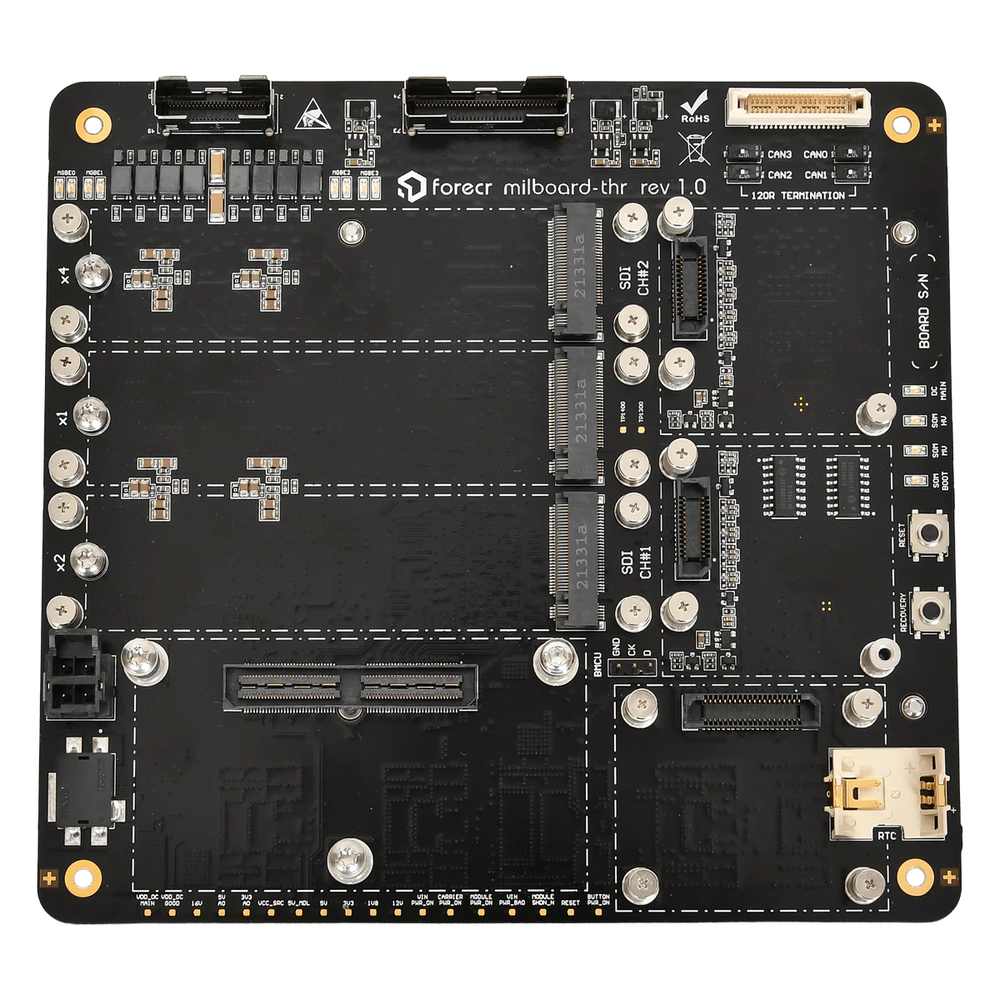
NVIDIA Jetson T5000 Military-Grade Rugged Carrier Board with Quad 10GbE and Isolated CAN FD
- AI
- 2,070 TOPS
- SOM
- NVIDIA Jetson T5000
- Ethernet
- 4× 10GbE
Thor builds compared
The facts below come from each product’s own specification.
| System | Module | Networking | Power input | Rated environment |
|---|---|---|---|---|
| Advantech MIC-742-AT-T5000 | Jetson T5000, 128 GB | Four 25GbE on QSFP28, 5GbE RJ45, four CAN FD | 19–36 V DC | −10 °C to 60 °C with 0.7 m/s airflow |
| Forecr DSBOX‑THRMAX‑T4000 | Jetson T4000, 64 GB | Four 25GbE on QSFP28, GbE RJ45 | 18–32 V DC | −25 °C to 55 °C; optional eight GMSL2 inputs |
| Vecow EAC-7000-T4000 | Jetson T4000, 64 GB | Two 2.5GbE, M12 X-coded option | 9–50 V DC with ignition control | Fanless to 45 °C in 77 W mode; MIL-STD-810G shock and vibration |
| Forecr MILBOARD‑THR‑T5000 | Jetson T5000, 128 GB | Four 10GBASE-T, isolated CAN FD | 18–36 V DC | Board rated −40 °C to 85 °C |
Each runs JetPack 7. We fit the storage, wireless and camera options, set the power mode to suit the enclosure and image the system with the release your application is validated on.
Is your project ready for Thor?
Seven questions that decide between staying on AGX Orin and moving to Thor.
-
01
Model size
Do the models, context and buffers fit in 64 GB, or do they need 128 GB?
-
02
Precision
Will the models hold accuracy at FP4 or FP8, where Blackwell gains most?
-
03
Power budget
Can the supply, battery and wiring deliver up to 130 W plus the carrier?
-
04
Cooling
Is the enclosure designed for the chosen Thor power mode at the hottest ambient?
-
05
Sensors
Will 25GbE, Holoscan Sensor Bridge or MIG change the sensor architecture?
-
06
Software
Is the team ready to move to JetPack 7 and rebuild every engine?
-
07
Lifecycle
Does the programme need Thor’s longer runway, or does Orin’s cover it?
Jetson Thor vs Orin: common questions
Quick answers
What is Jetson Thor?
NVIDIA’s newest Jetson generation, on the Blackwell GPU. The T5000 and T4000 modules are rated at up to 2,070 and 1,200 FP4 TFLOPS, with 128 and 64 GB of memory.
What is the difference between Jetson Thor and AGX Orin?
A new GPU, CPU, memory and connector. Thor moves to Blackwell, Neoverse-V3AE cores and LPDDR5X, at 40–130 W against 15–60 W for AGX Orin 64GB.
How many TOPS is Jetson Thor?
NVIDIA quotes FP4 TFLOPS rather than INT8 TOPS. The T5000 is rated at up to 2,070 sparse FP4 TFLOPS and the T4000 at 1,200.
How much power does Jetson Thor use?
40–130 W for the T5000 module. The T4000 runs at 40–70 W; a complete system draws more.
Is Jetson Thor compatible with Orin carrier boards?
No. Thor needs a carrier designed for its connector, power and I/O.
What is Jetson T5000 vs T4000?
The two Thor modules. The T5000 has 128 GB and more GPU and CPU cores; the T4000 has 64 GB and a 70 W ceiling.
When is Jetson Thor available?
Now. The AGX Thor developer kit and T5000 arrived in August 2025, the T4000 followed, and Thor systems are in production.
Jetson Thor FAQs
-
Does Jetson Thor Need a New Carrier Board?
Yes. The NVIDIA Jetson Thor module uses a different connector, higher power (up to 130 W) and new I/O compared with AGX Orin, so it needs a carrier board designed for Thor rather than an Orin board. Moving from AGX Orin to Thor is a platform change, not a drop-in module swap.
-
Jetson T5000 vs T4000: What Is the Difference?
The Jetson T5000 and T4000 are the two NVIDIA Jetson Thor modules, both built on the Blackwell GPU. The T5000 is the top variant, with up to 2,070 FP4 TFLOPS, 128 GB of memory and up to 130 W. The T4000 is the lower-power variant, with up to 1,200 FP4 TFLOPS, 64 GB and up to 70 W.
-
What Is NVIDIA Blackwell?
NVIDIA Blackwell is the GPU architecture NVIDIA announced in March 2024 to follow Hopper and Ada Lovelace. It powers B200 and GB200 data centre accelerators, RTX PRO Blackwell workstation and embedded GPUs, GeForce RTX 50 cards and the Jetson Thor edge AI modules, and adds fifth-generation Tensor Cores with 4-bit (FP4) AI.
-
What Is NVIDIA MIG?
NVIDIA MIG (Multi-Instance GPU) splits one data centre GPU into as many as seven smaller GPUs, each with its own compute cores, cache and memory. Each instance runs its own workload in isolation with predictable performance, so one physical GPU can serve several users, models or inference services at once.
-
What Is NVIDIA Holoscan?
NVIDIA Holoscan is NVIDIA’s sensor-processing platform for real-time AI on streaming data at the edge. It combines the open-source Holoscan SDK, which builds low-latency pipelines from capture to inference to display, with the Holoscan Sensor Bridge for bringing camera and sensor data over Ethernet straight into GPU memory, on Jetson, IGX and x86 GPU systems.
-
What Is a Teraflop (TFLOPS), and How Is It Different From TOPS?
A teraflop is one trillion floating-point operations per second, and TFLOPS counts them: a measure of how fast a processor handles decimal maths at a stated precision such as FP32. TOPS counts trillions of operations per second, usually integer maths at INT8. GPUs quote TFLOPS for graphics and general compute, while NPUs and AI accelerators quote TOPS for inference.
-
What Is a Humanoid Robot?
A humanoid robot is a robot built in roughly human form, usually with a head, a torso, two arms and two legs, so it can work in spaces and with tools designed for people. Modern humanoid robots use cameras, AI models and an onboard computer to walk, balance and handle objects.
Designing around Jetson Thor?
Tell us about the models, sensors and power budget, and where the system has to run. We will recommend Thor or AGX Orin and the system around it, then configure, image and test it before it ships.