 UK
Stereo Cameras
3D Depth Cameras for Navigation, Mapping and Robot Arms
A depth camera built on stereo vision measures distance from two matched image sensors, giving a robot a 3D view of its surroundings for navigation, mapping and picking. With no active emitter it keeps working outdoors in sunlight, and the range runs from close-range cameras for robot wrists to long-baseline models that see tens of metres ahead.
Options include global shutter sensors for fast motion, wide and narrow lenses, polarizer filters for glare on glass and water, IP66 and IP67 housings and built-in IMUs for positional tracking, suited to autonomous mobile robots, manipulation, agriculture and spatial analytics where accuracy has to hold up on a moving machine.
Speak to a stereo camera specialist to match depth range, baseline and interface to your robot.


Browse Our Stereo Depth Cameras
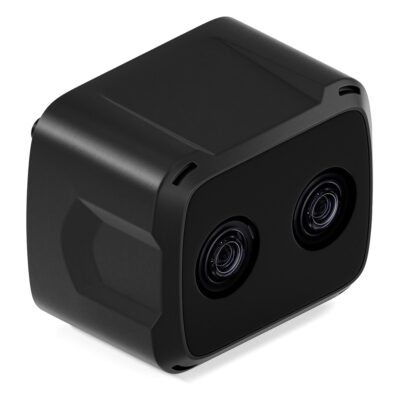
- Camera: Stereo
- Interface: GMSL2 [FAKRA Z]
- Sensor: Dual 2.3MP 1/2.6" [3µm]
- Shutter: Global Shutter
- Depth Range: 0.03 to 2m
- Temp: 0°C to 50°C [32°F to 122°F]
- Certification: REACH, RoHS, TSCA
- Mounting Options: Tripod Mount
-
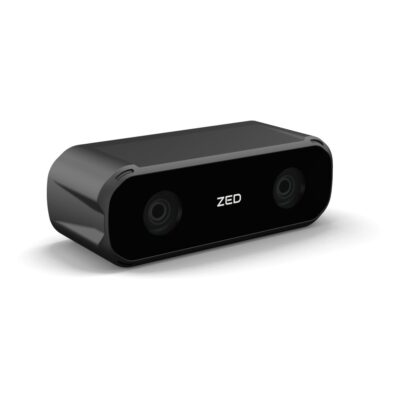
ZED-X-MINI-NARROW
ZED-X-MINI-NARROW with narrow 4.6 mm lenses, 0.15 to 12 m depth and GMSL2 -
ZED-X-MINI-NARROW-POL
ZED-X-MINI-NARROW-POL with narrow 4.6 mm lenses, built-in polarizer and 12 m depth -
ZED-X-MINI-WIDE
ZED-X-MINI-WIDE with wide 2.2 mm lenses, 5 cm baseline, GMSL2 and IP67 -
ZED-X-MINI-WIDE-POL
ZED-X-MINI-WIDE-POL with wide 2.2 mm lenses, built-in polarizer, 5 cm baseline and GMSL2
- Camera: Stereo
- Interface: GMSL2 [FAKRA Z]
- Sensor: Dual 2.3MP 1/2.6" [3µm]
- Shutter: Global Shutter
- Temp: -20°C to 60°C [-4°F to 140°F]
- IP Rating: IP67
- Certification: CE, EMC, FCC, IC (ICES-003), REACH, RoHS, TSCA
- Mounting Options: Tripod Mount
- Depth Range: 0.15 to 12m
-
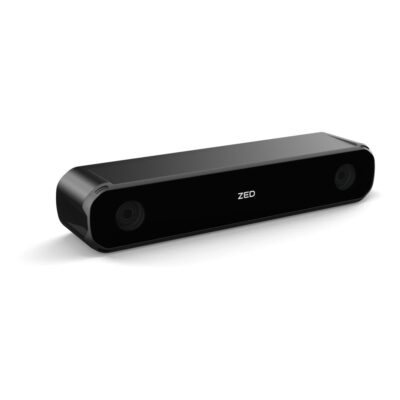
ZED-X-NARROW
ZED-X-NARROW with narrow 4.6 mm lenses, 1 to 35 m depth, GMSL2 and IP67 -
ZED-X-NARROW-POL
ZED-X-NARROW-POL with narrow 4.6 mm lenses, built-in polarizer, GMSL2 and 35 m depth -
ZED-X-WIDE
ZED-X-WIDE with wide 2.2 mm lenses, global shutter, GMSL2 and IP67 -
ZED-X-WIDE-POL
ZED-X-WIDE-POL with wide 2.2 mm lenses, built-in polarizer, GMSL2 and IP67
- Camera: Stereo
- Interface: GMSL2 [FAKRA Z]
- Sensor: Dual 2.3MP 1/2.6" [3µm]
- Shutter: Global Shutter
- Temp: -20°C to 60°C [-4°F to 140°F]
- IP Rating: IP67
- Certification: CE, EMC, FCC, IC (ICES-003), REACH, RoHS, TSCA
- Mounting Options: Tripod Mount
- Depth Range: 1.0 to 35m
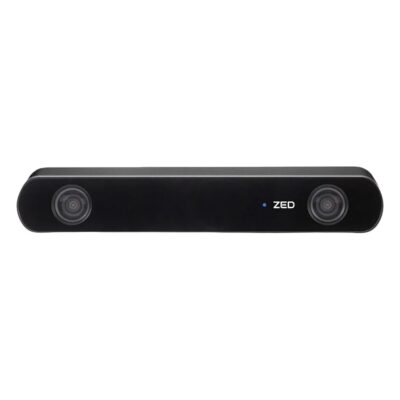
-
ZED-2I-NARROW-POL
ZED-2I-NARROW-POL with narrow 4.6 mm lenses, built-in polarizer and 35 m depth -
ZED-2I-NARROW
ZED-2I-NARROW with narrow 4.6 mm lenses, 0.5 to 35 m depth and USB 3.0 -
ZED-2I-WIDE
ZED-2I-WIDE with wide 2.1 mm lenses, 120° field of view, USB 3.0 and IP66 -
ZED-2I-WIDE-POL
ZED-2I-WIDE-POL with wide 2.1 mm lenses, built-in polarizer, USB 3.0 and IP66
- Camera: Stereo
- Interface: USB 3.0 [Type C]
- Sensor: Dual 4MP 1/3" [2µm]
- Shutter: Rolling Shutter
- Temp: -10°C to 45°C [14°F to 113°F]
- IP Rating: IP66
- Certification: CE, REACH, RoHS, TSCA
- Mounting Options: Tripod Mount
- Depth Range: 0.5 to 35m
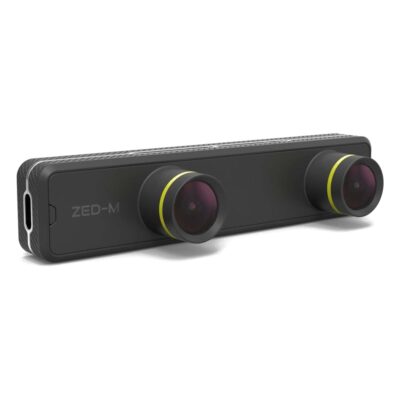
- Camera: Stereo
- Interface: USB 3.0 [Type C]
- Sensor: Dual 4MP 1/3" [2µm]
- Shutter: Rolling Shutter
- Depth Range: 0.1 to 15m
- Temp: 0°C to 45°C [32°F to 113°F]
- Certification: CE, REACH, RoHS, TSCA
Stereo Camera Ranges Configured by Things Embedded
We work with Stereolabs, the maker of the ZED stereo cameras, so the ranges below are the depth cameras we specify for navigation, mapping and manipulation. Compare them by baseline and depth range, then browse the cameras above or ask a stereo vision specialist.
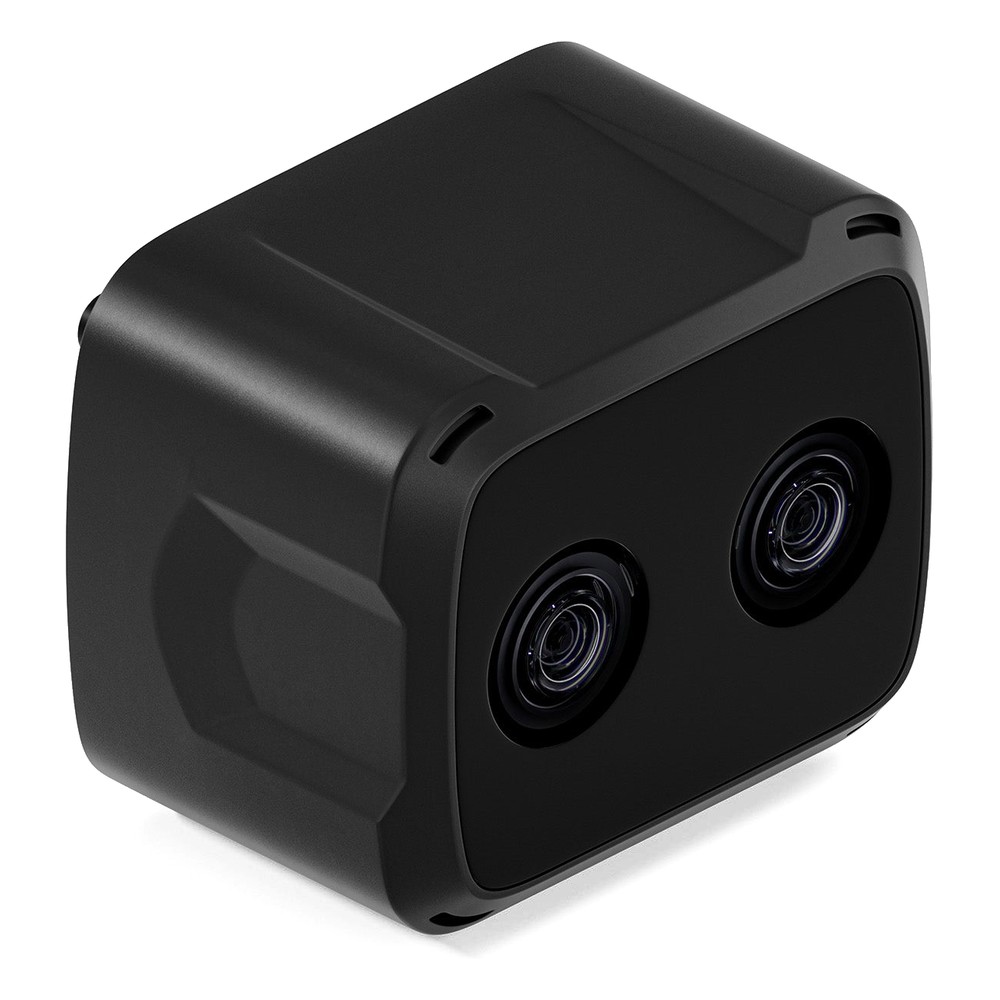
ZED X Stereolabs IP67 Stereo Cameras
Global shutter GMSL2 cameras with a 120 mm baseline, wide or narrow lenses and an optional polarizer, seeing depth out to 35 m.
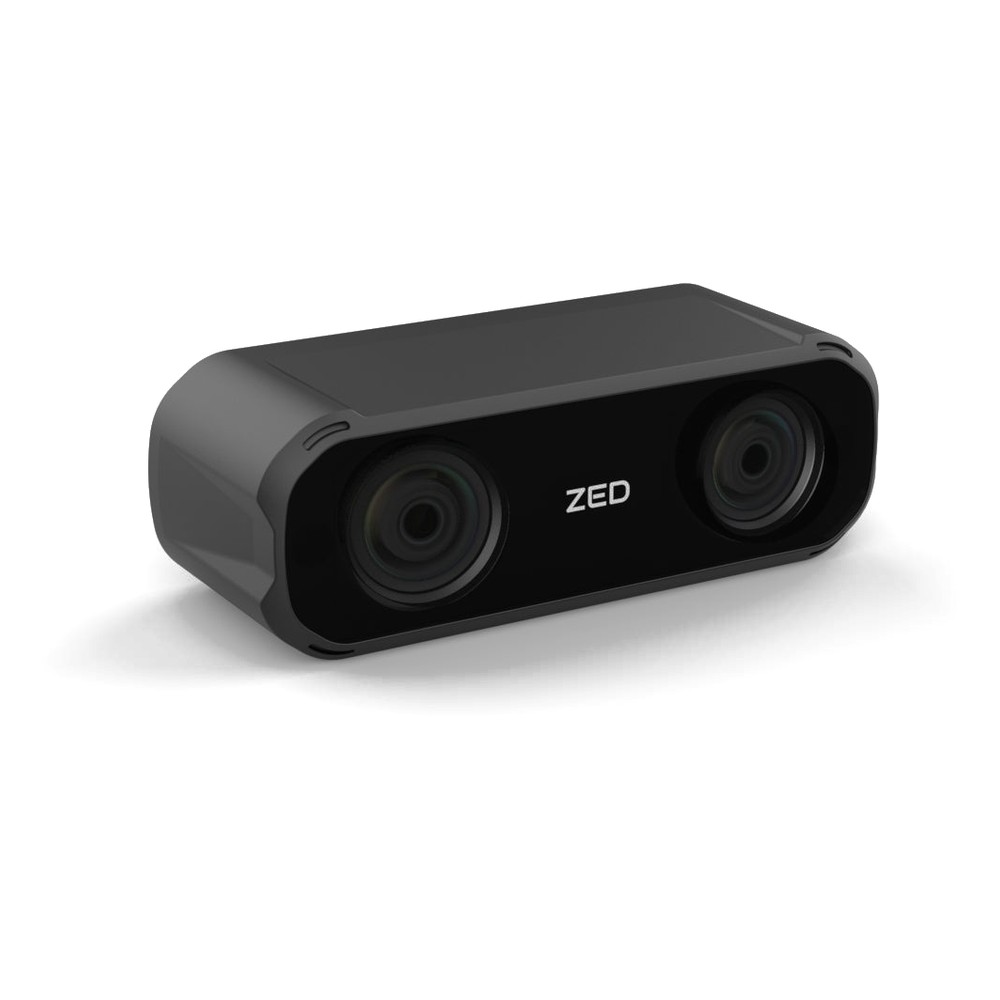
ZED X Mini Stereolabs 3D Depth Cameras
Short 50 mm baseline GMSL2 depth cameras for arms and small robots, sealed to IP67 with wide or narrow lenses.
ZED X Nano Stereolabs Close-Range Stereo Camera
Wrist-sized global shutter camera measuring from 3 cm to 2 m for grasping, picking and manipulation.
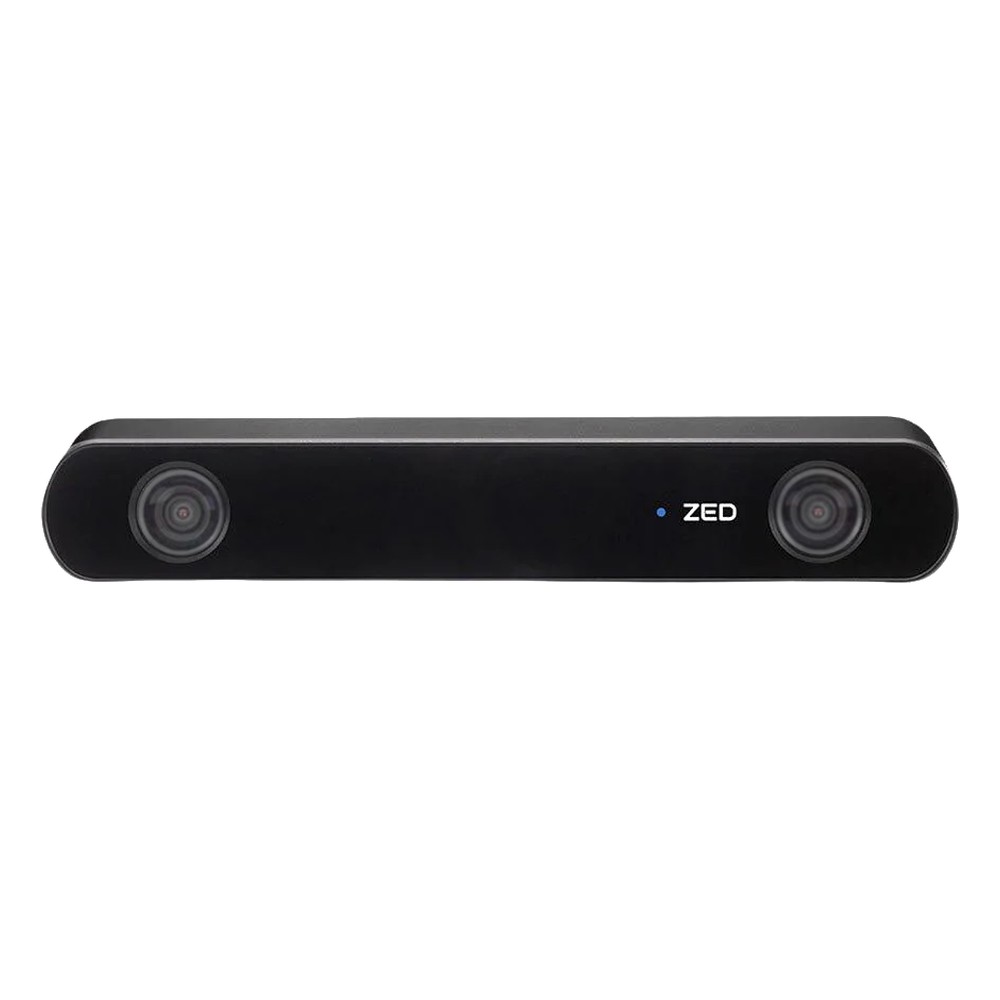
ZED 2i Stereolabs USB Stereo Depth Cameras
IP66 USB 3.0 depth cameras with an IMU, barometer and magnetometer, wide or narrow lenses and optional polarizer.
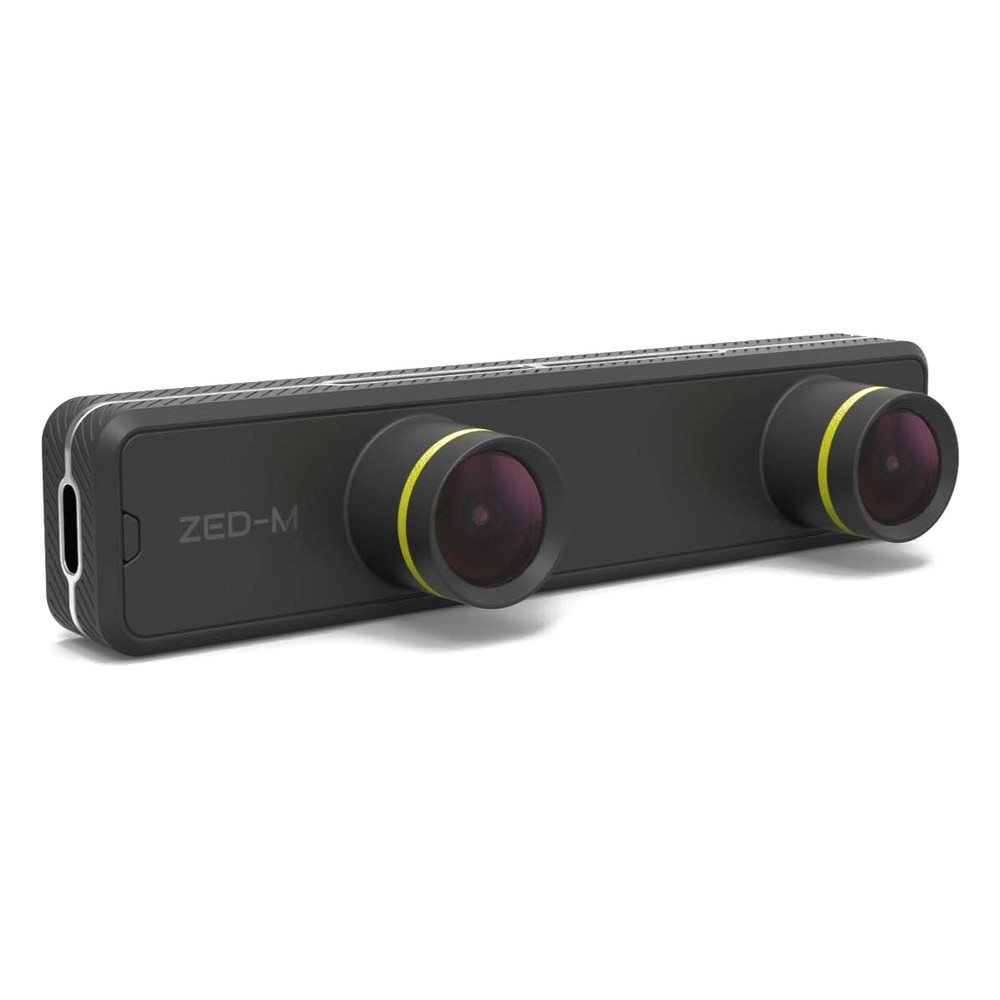
ZED Mini Stereolabs Mini Stereo Camera
Light USB stereo camera with a 63 mm baseline for headsets, small robots and close-range mapping.
Not sure which range fits? Tell us the application and we will recommend the right model.
What to Specify in a Stereo Vision Camera
Our vision specialists specify every stereo camera against the distances it has to measure, the motion of the machine and the host that processes the depth. These are the choices we work through with you.
Depth Range and Baseline
Short baselines resolve centimetres in front of a gripper; 120 mm baselines measure tens of metres ahead.

Lens and Field of View
Wide lenses cover more of the scene up close; narrow lenses keep depth accurate further out.

Global or Rolling Shutter
Global shutter avoids skew on fast robots and vehicles; rolling shutter offers higher resolution for slower scenes.
USB or GMSL2
USB 3.0 for development and short runs; GMSL2 coax for vibration, EMI and long cables on the machine.

Polarizer
A polarizer cuts glare from glass, water and polished metal that would otherwise break the depth map.
Sealing and Temperature
IP66 and IP67 housings for outdoor robots, with the operating range checked against the site.
Explore Cameras, Capture Cards and Jetson Hosts
Compare every vision camera, move across to GMSL2 models, or pick the capture card and NVIDIA Jetson computer that runs the depth processing.
Depth Camera Innovation & Robotics Insights




Speak to a Stereo Camera Specialist.
Tell us the distances your robot needs to measure, how fast it moves and where it works. We will recommend the right stereo camera and Jetson host, then configure and test the system before it ships.