 US
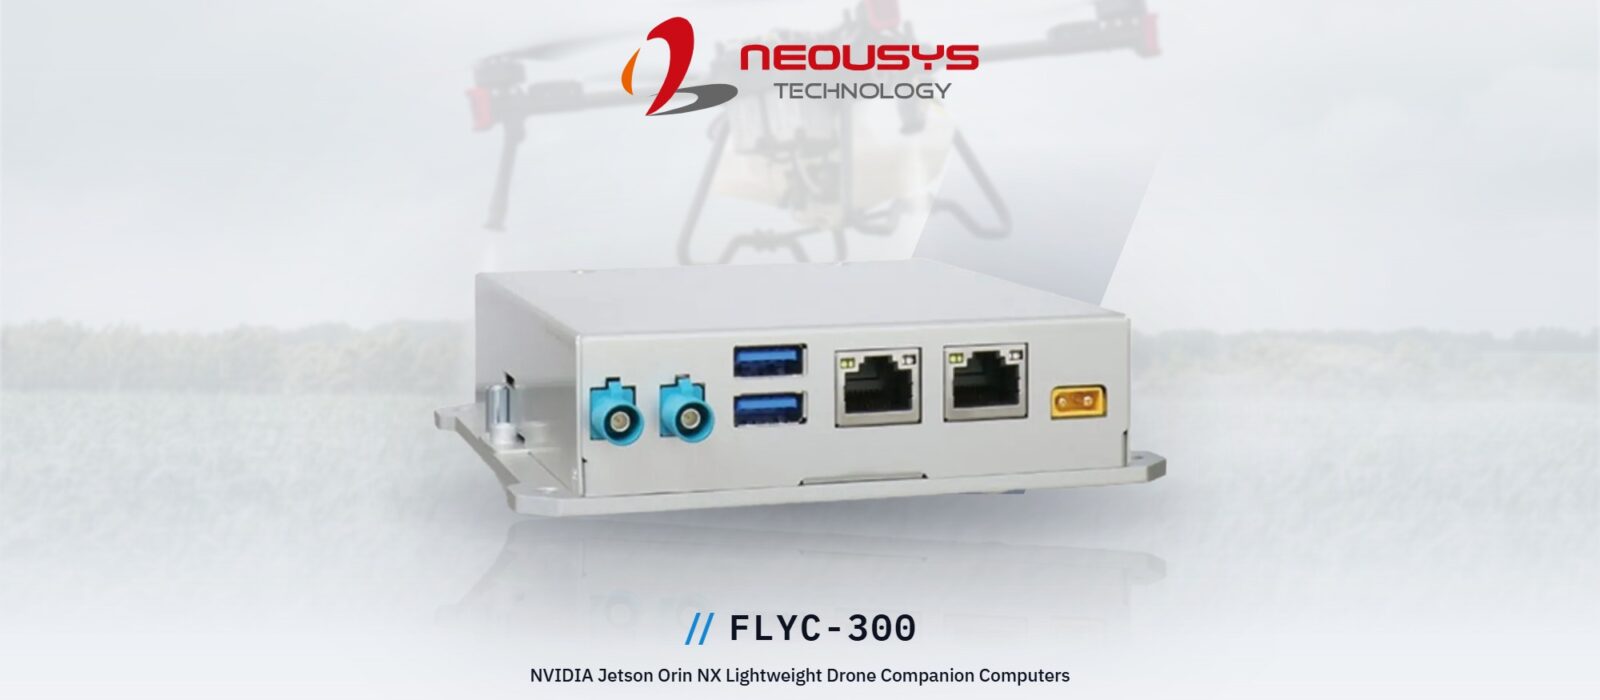
Neousys FLYC-300: a low-SWaP Jetson Orin NX mission computer for drones
The Neousys FLYC-300 puts up to 100 TOPS of NVIDIA Jetson Orin NX AI onto a drone in a 297-gram package, with the cameras, sensors, and flight-controller interfaces a UAV needs.
Neousys has designed the FLYC-300 for one job: putting NVIDIA Jetson AI onto a drone. It is a low-SWaP mission computer powered by the Jetson Orin NX, delivering up to 100 TOPS of AI at 297 g in its board-level form. We supply the FLYC-300 for UAV and UGV integration.
It works alongside the flight controller, the part that stabilizes and flies the aircraft, as the companion computer that handles the autonomy: navigation, obstacle avoidance, and object detection and tracking. Keeping size, weight and power low leaves more of the budget for payload and flight time.
What the FLYC-300 brings
- 01Up to 100 TOPS
- NVIDIA Jetson Orin NX in 8 GB or 16 GB, for real-time vision and autonomy.
- 02297 g board-level
- A heat-spreader build that mounts directly to the airframe, or an enclosed build at 345 g with antenna exits.
- 03Two GMSL2 cameras
- FAKRA Z inputs for HDR and 3D cameras, plus GbE, 2.5GbE and USB 3.2 for RGB, infrared, hyperspectral, LiDAR and radar.
- 04Flight-controller ready
- UART, CAN 2.0 and Ethernet to communicate with ArduPilot or PX4 controllers, plus I2C and isolated DI/DO.
- 05Drone-battery power
- A 12–60 V DC input over XT-30 for 4S to 14S packs, with M.2 for a 4G or 5G downlink.
FLYC-300, iBOX-604-G2 and MILBOX‑ORNX compared
| Specification | Neousys FLYC-300 | Sintrones iBOX-604-G2 | Forecr MILBOX‑ORNX |
|---|---|---|---|
| Build | Board-level on a heat spreader, or enclosed | Fanless aluminum enclosure | Sealed IP67 enclosure |
| Weight | 297 g board-level; 345 g enclosed | Under 339 g | 1.9 kg |
| Module | Jetson Orin NX 16 / 8 GB | Jetson Orin NX 16 / 8 GB, Orin Nano 8 GB | Jetson Orin NX 16 / 8 GB, Orin Nano 8 / 4 GB |
| AI performance | Up to 100 TOPS | Up to 100 TOPS | Up to 157 TOPS (Super mode) |
| Cameras | 2× GMSL2 on FAKRA Z | 2× GMSL2 on FAKRA | Camera expansion connector; optional 4× GMSL2 on HD-BNC |
| Power input | 12–60 V DC on XT-30, 4S to 14S packs | 10–60 V DC on terminal block, 3S to 14S packs, ignition detection | 9–40 V DC (28 V nominal), military-grade filtering |
| Flight-controller interfaces | Internal UART, CAN 2.0, I2C | CAN FD, 3.3 V UART, 1× RS-232/422/485 | 2× CAN bus, 2× RS-232/422/485 |
| Operating temperature | −25 to 40 °C; to 70 °C with the heat spreader secured to aluminum and 4S to 6S packs | −25 to 55 °C with 0.6 m/s airflow (to 50 °C on Orin NX 16 GB) | −25 to 85 °C |
| Standards | MIL-STD-810H vibration and shock | MIL-STD-810H shock and vibration | MIL-STD-461G / 704F / 1275E, DO-160G, IP67 |
Pick the FLYC-300 when every gram counts: at 297 g on its heat spreader it is the lightest of the three, as long as the airframe’s aluminum structure can take the heat away.
Pick the iBOX-604-G2 when you want a ready enclosure under 339 g with CAN FD to the flight controller, or an Orin Nano build for lighter models.
Pick the MILBOX‑ORNX when the platform has to meet military EMI and power standards or needs IP67 sealing, and can carry 1.9 kg in return for up to 157 TOPS.
FLYC‑300 variants
Four variants: Orin NX 16 GB or 8 GB, each as a board-level build on its heat spreader or inside an enclosure with three antenna holes.
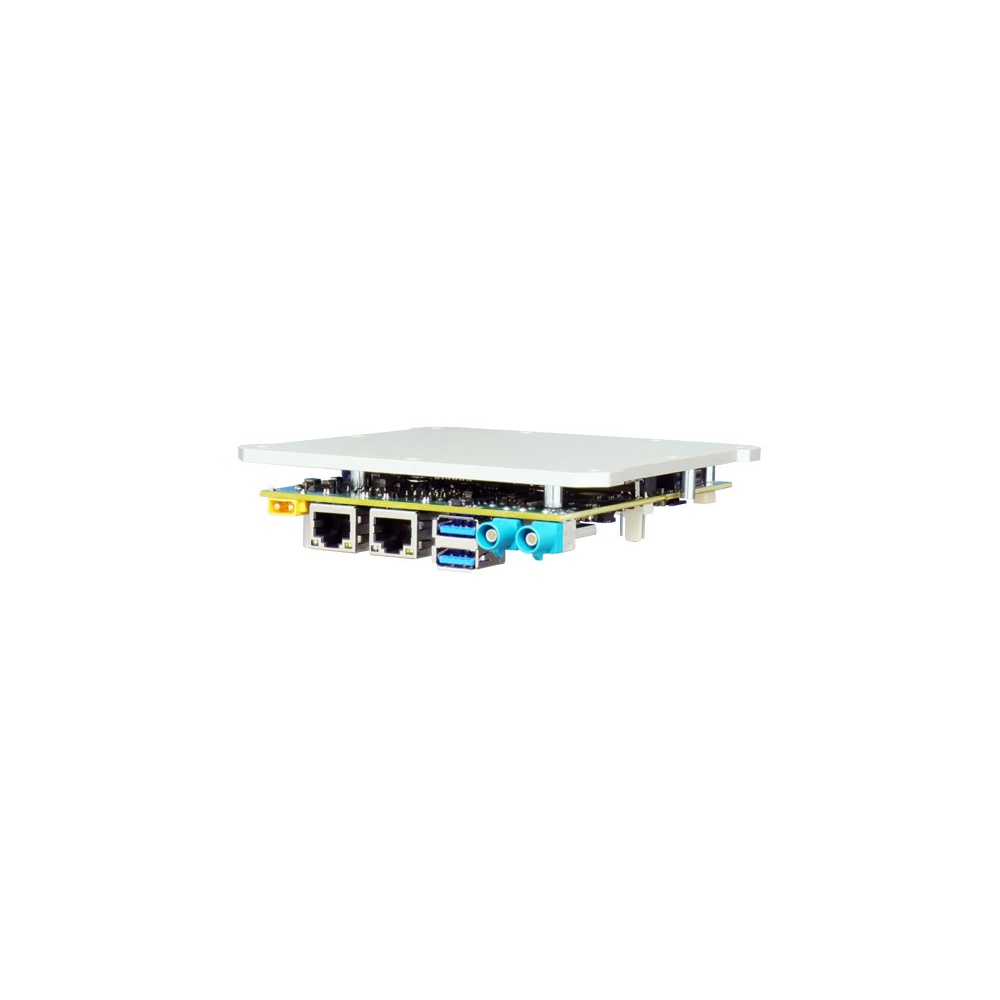
NVIDIA Jetson Orin NX 16GB Board-Level Drone Companion Computer with 2x GMSL2
- AI
- 100 TOPS
- SOM
- NVIDIA Jetson Orin NX 16 GB
- Cameras
- 2× GMSL
NVIDIA Jetson Orin NX 8GB Board-Level Drone Companion Computer with 2x GMSL2
- AI
- 70 TOPS
- SOM
- NVIDIA Jetson Orin NX 8 GB
- Cameras
- 2× GMSL
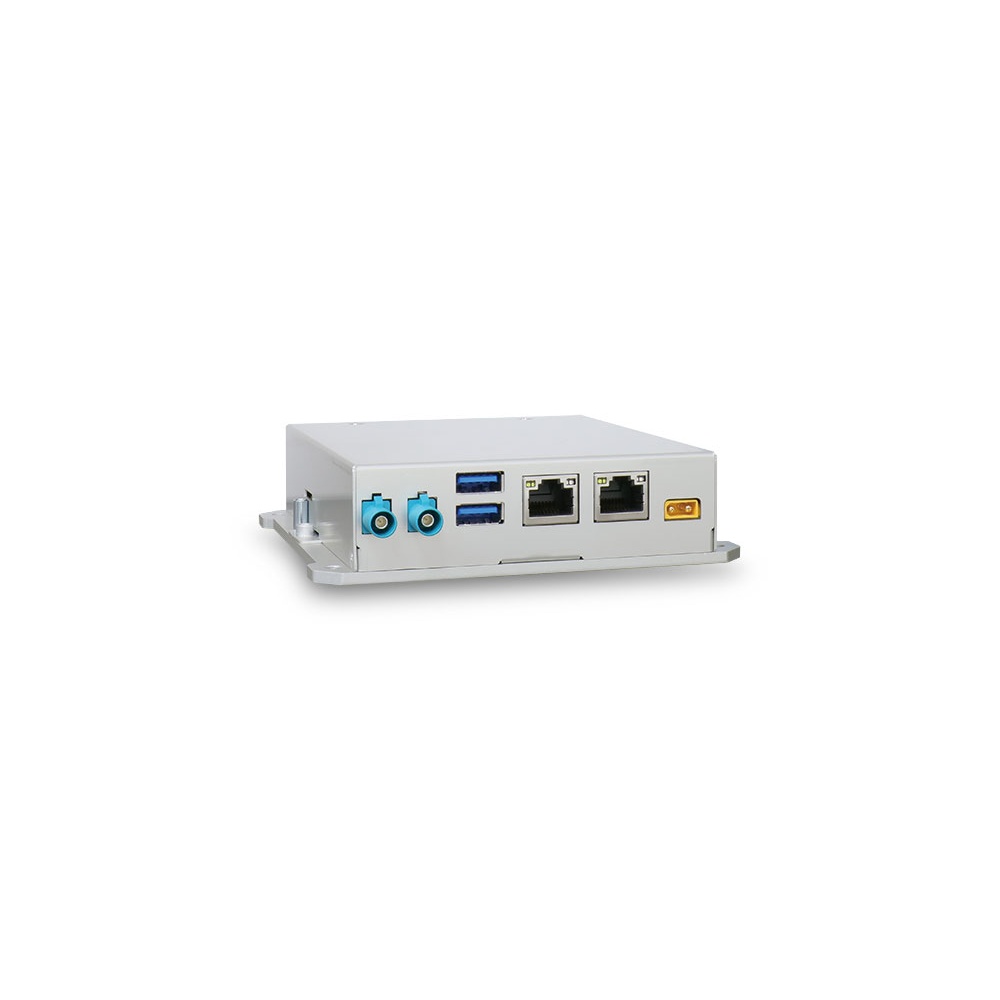
NVIDIA Jetson Orin NX 16GB Enclosed Drone Companion Computer with 2x GMSL2
- AI
- 100 TOPS
- SOM
- NVIDIA Jetson Orin NX 16 GB
- Cameras
- 2× GMSL
NVIDIA Jetson Orin NX 8GB Enclosed Drone Companion Computer with 2x GMSL2
- AI
- 70 TOPS
- SOM
- NVIDIA Jetson Orin NX 8 GB
- Cameras
- 2× GMSL
A closer look
-
01
Enclosed mission computer
The FLYC-300 in its aluminum enclosure, with GMSL2, USB 3.2, dual RJ45 and the XT-30 power input.
-
02
Board-level build
The 297 g board-level FLYC-300 on its heat spreader, showing the RJ45, USB 3.2 and GMSL2 ports.
From module to mission
A drone computer is only useful once it is integrated: cameras configured, the flight-controller link working, power drawn cleanly from the battery and the module held thermally inside the airframe.
-
Configure
Module and formWe recommend the Orin NX memory and the board-level or enclosed build to fit the mission and the airframe.
-
Sensors
Cameras and payloadCameras for depth and obstacle avoidance go on the two GMSL2 inputs, and RGB, thermal, hyperspectral or LiDAR sensors on Ethernet and USB, configured for the payload.
-
Link
Flight controllerThe flight-controller link to ArduPilot or PX4 is brought up over UART, CAN or Ethernet.
-
Mount
Thermal and powerThe heat spreader mounting and battery input are planned together, following our Jetson thermal design guide, and the system is tested before delivery.
Related reading
For the wider picture, see our guide to choosing a Jetson companion computer for drones. In defense work, drone AI often serves intelligence, surveillance and reconnaissance; how Airbus Defense and Space runs ISR drone video analytics on a rugged Jetson AGX Orin computer shows one deployed system.
FLYC-300 FAQs
-
What Is a Drone Companion Computer?
A drone companion computer is a small AI computer that runs alongside the flight controller on a UAV. The flight controller flies the aircraft; the companion computer does the thinking — running computer vision and AI to give the drone autonomy such as obstacle avoidance, navigation, and object detection. NVIDIA Jetson is the common choice because it delivers high AI performance at a weight light enough to fly.
-
How Does a Jetson Connect to a Flight Controller?
An NVIDIA Jetson connects to a drone flight controller over a serial UART or a CAN bus, usually speaking the MAVLink protocol. The Jetson runs the autonomy software (often ArduPilot or PX4 companion software) and sends commands, waypoints, and position estimates to the flight controller, which executes them and returns telemetry.
-
Which NVIDIA Jetson Is Best for a Drone?
For most drones the NVIDIA Jetson Orin NX is the sweet spot: up to 100 TOPS of AI in a low-power, lightweight module, enough for multi-camera vision and autonomy. The lighter Orin Nano suits simpler payloads. The choice ultimately depends on the AI workload, the weight budget, and the flight time.
-
What Is SWaP-C?
SWaP-C stands for size, weight, power and cost. It is the design trade-off used in defense and aerospace to judge equipment for platforms with tight limits, such as drones and vehicles, where every gram, watt and pound spent reduces endurance, payload or budget.
-
What Does ISR Mean in the Military?
In the military, ISR stands for intelligence, surveillance and reconnaissance: the collection, processing and analysis of information about an area or target to support decisions. It is carried out by satellites, aircraft, drones, ships and ground sensors.
-
What Is a Stereo Camera?
A stereo camera is a camera with two image sensors set a fixed distance apart, like a pair of eyes. By finding the same point in both images and measuring how far it shifts between them, it calculates the distance to every pixel, so one sensor gives a robot or vehicle a 3D depth map as well as a color image.
-
MIL-STD-810G vs MIL-STD-810H: What Is the Difference?
MIL-STD-810G (2008) and MIL-STD-810H (2019) are successive revisions of the US military environmental test standard. 810H is the current version; it refined and reorganised test methods and tightened guidance, but both define test methods rather than a pass or fail certificate.
Building a Jetson drone?
Tell us the airframe, the payload, and the autonomy software. We supply the FLYC-300 and integrate it into a flight-ready Jetson platform.